1Nanjing University
2Huazhong University of Science and Technology
3University of Science and Technology of China 4Microsoft Research
5Institute for AI Industry Research (AIR), Tsinghua University
* Equal contribution
† Work done during internship at AIR, Tsinghua University
‡ Corresponding author
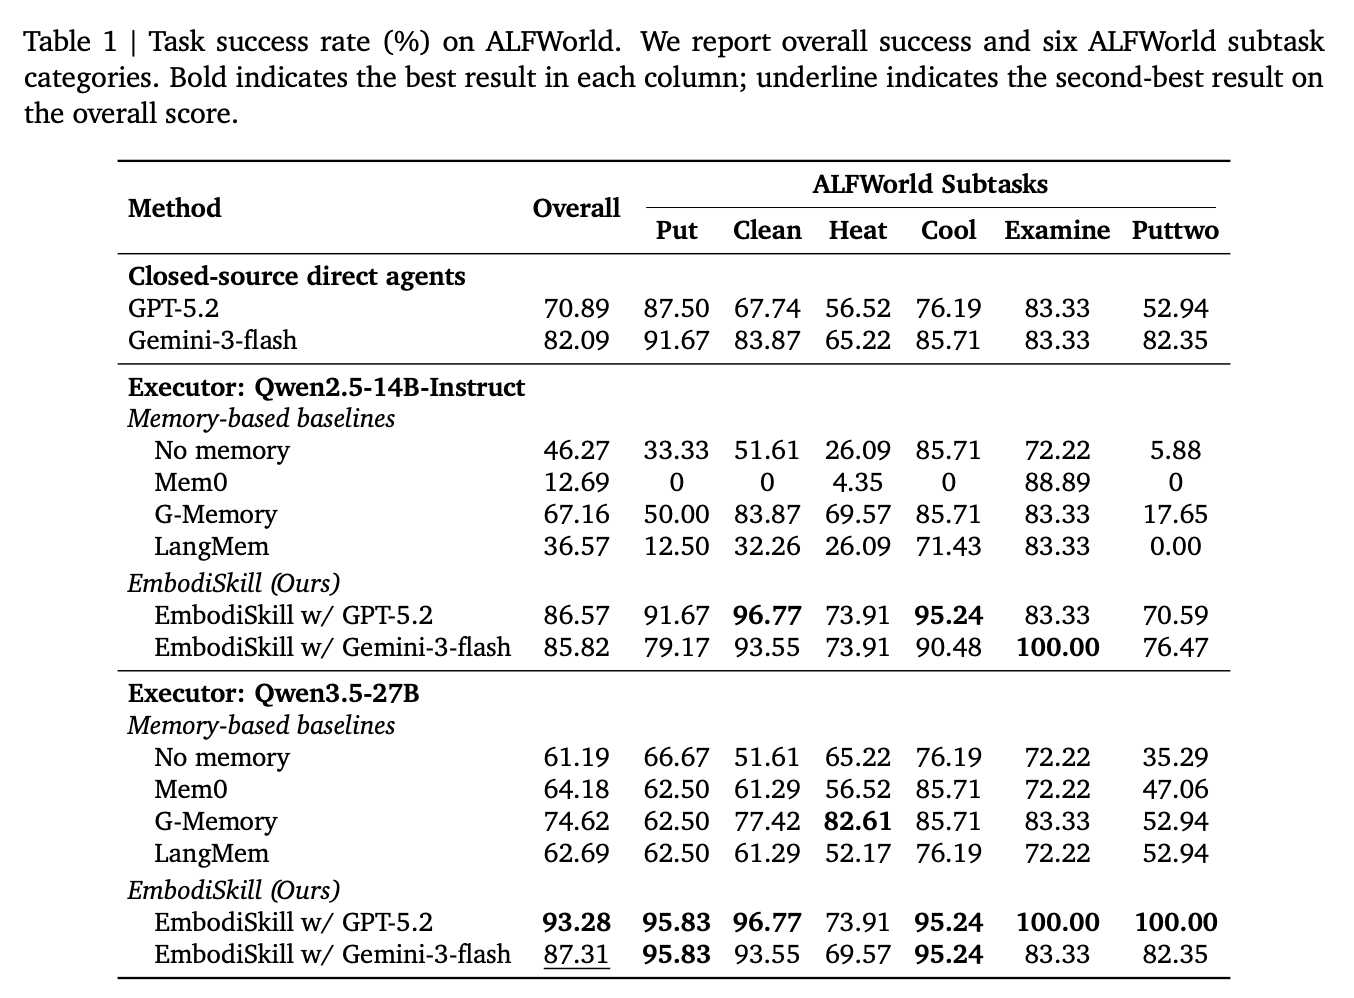
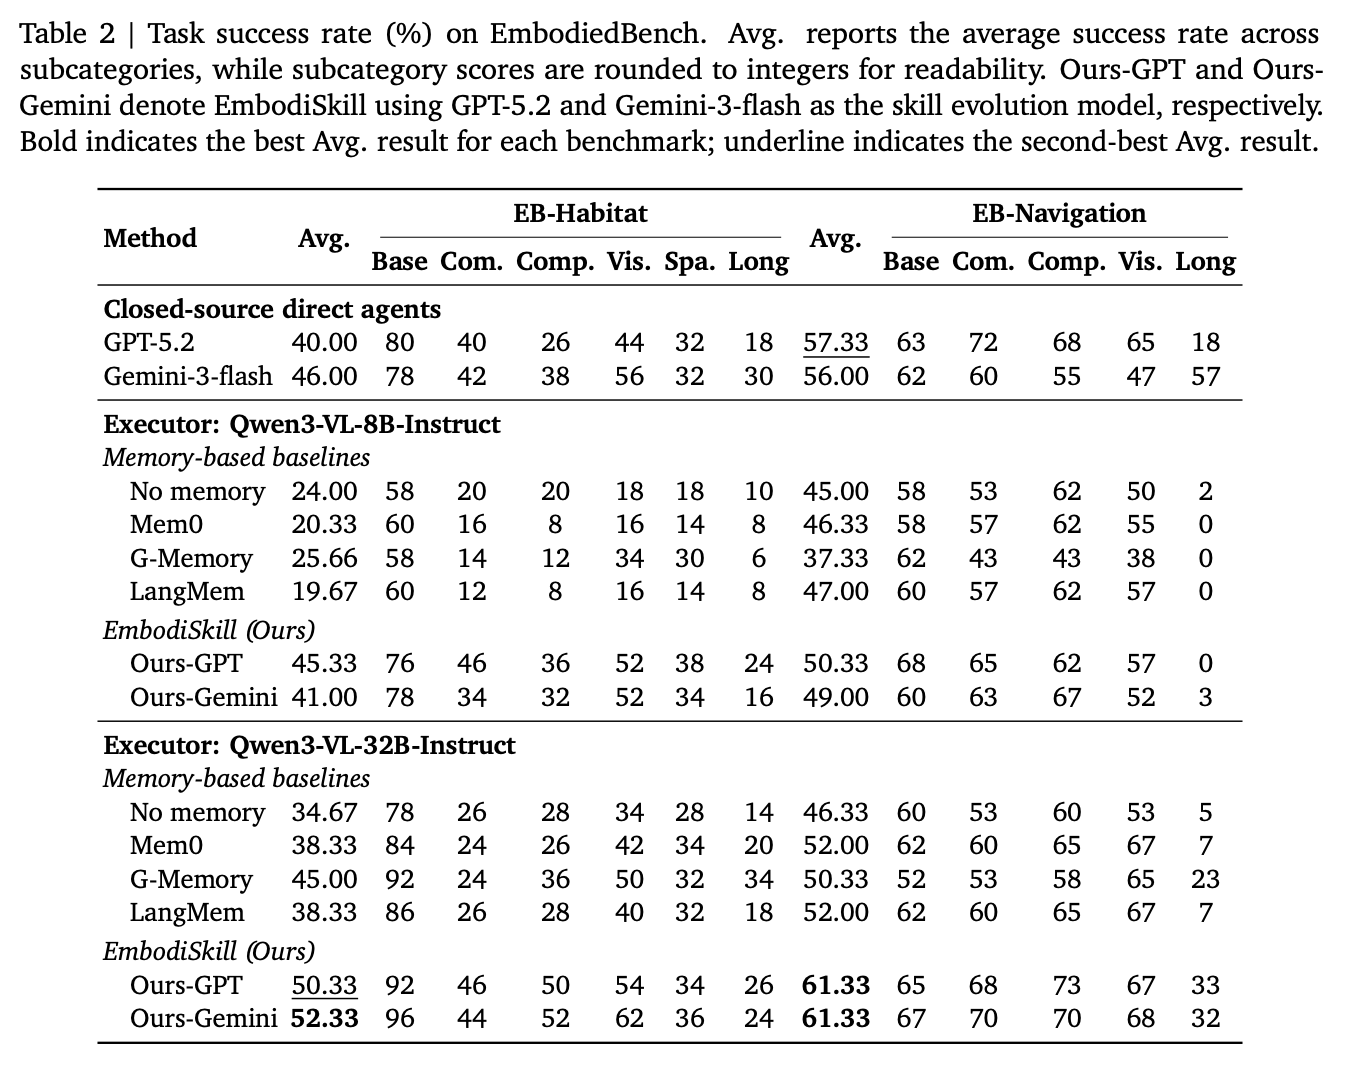
Embodied agents can benefit from skills that guide object search, action execution, and state changes across diverse environments. Since embodied environments vary across layouts, object states, and other execution factors, these skills must self-evolve from trajectories generated during task execution. However, existing skill self-evolution methods are mainly developed in digital environments and often convert trajectories into coarse skill updates. Directly applying this paradigm to embodied settings is problematic, because a failed task execution may reflect not only incorrect skill content, but also an execution lapse in which the agent fails to follow valid guidance. We propose EmbodiSkill, a training-free framework for embodied skill self-evolution through skill-aware reflection and targeted revision. EmbodiSkill interprets each trajectory with respect to the current skill, uses skill-changing evidence to update the skill body, and uses execution-lapse evidence to preserve and emphasize valid guidance. Experiments on ALFWorld and EmbodiedBench show that EmbodiSkill consistently improves embodied task success. On ALFWorld, EmbodiSkill enables a frozen Qwen3.5-27B executor to reach 93.28% task success, outperforming GPT-5.2 used as a direct agent without skills by 31.58%. These results show that skill-aware self-evolution helps embodied agents accumulate reusable procedural knowledge from their own trajectories.
Method
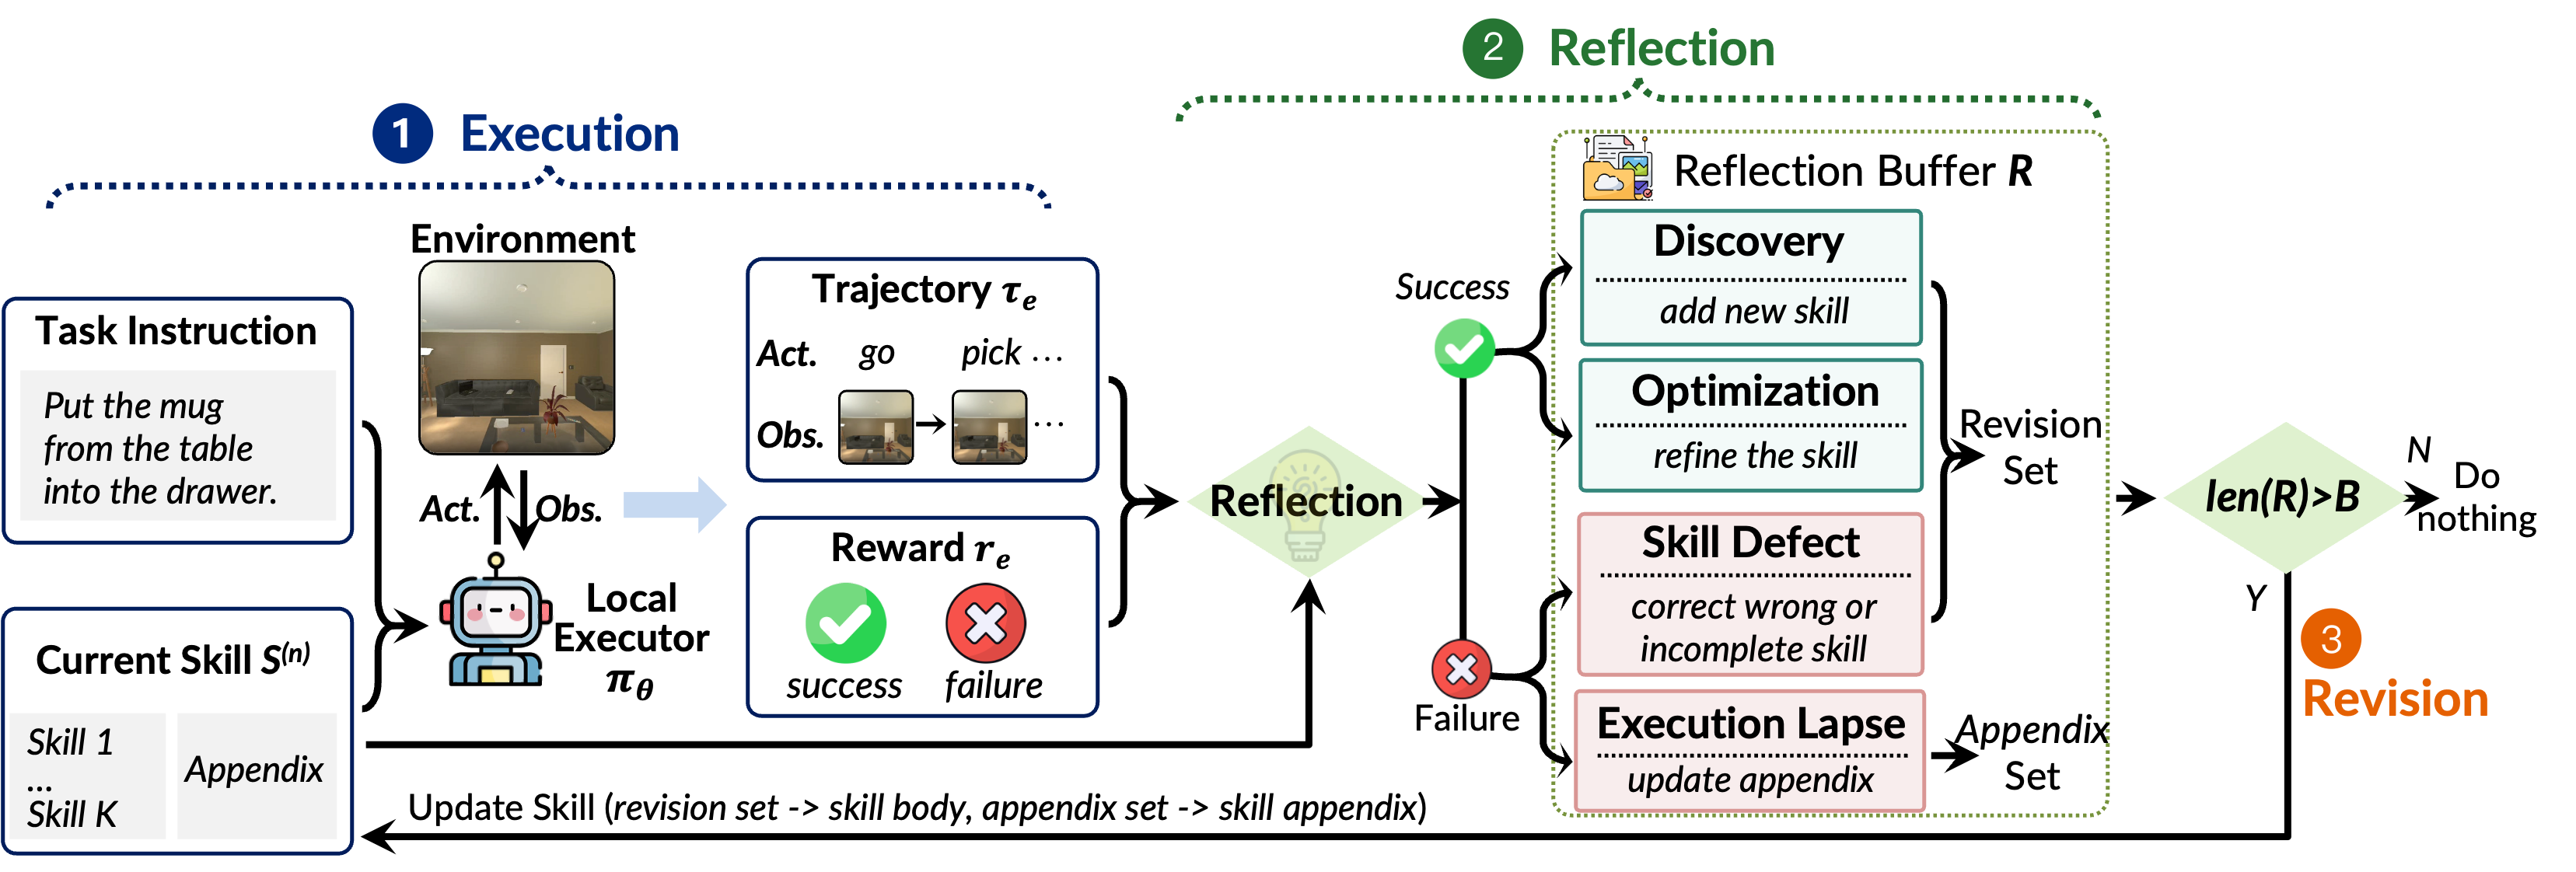
Figure 2: Overview of EmbodiSkill. The executor uses the current skill to perform embodied tasks and generate trajectories. Skill-aware reflection uses each trajectory to produce targeted reflection records. Accumulated reflections are consolidated into body-level revisions and skill-appendix updates, forming the next skill version. The revised skill then guides subsequent task execution, creating a Skill-Aware Evolution Spiral.
Experiments
ALFWorld Results
EmbodiedBench Results
Citation
@misc{ju2026embodiskill,
title={EmbodiSkill: Skill-Aware Reflection for Self-Evolving Embodied Agents},
author={Ju, Ruofei and Wang, Xinrui and Ding, Xin and Yang, Yifan and Wu, Hao and Jiang, Shiqi and Zhang, Qianxi and Wen, Hao and Li, Xiangyu and Wang, Weijun and Li, Kun and Liu, Yunxin and Dai, Haipeng and Wang, Wei and Cao, Ting},
year={2026},
eprint={2605.10332},
archivePrefix={arXiv},
primaryClass={cs.AI}
}